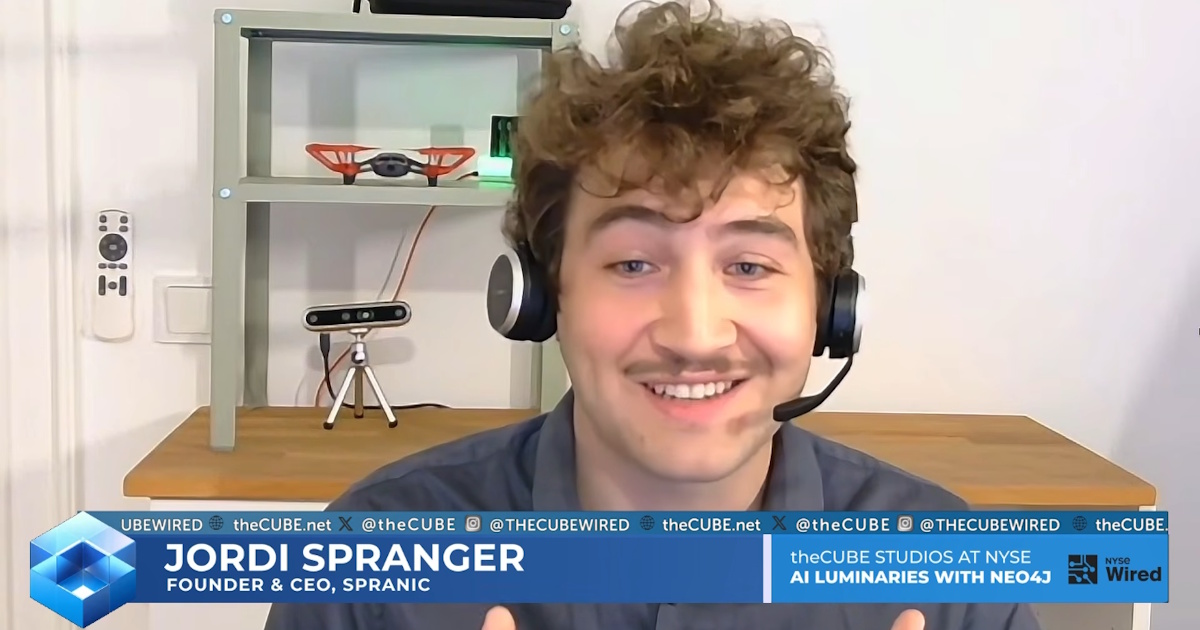
Physical AI needs context about its surroundings to adapt beyond a fixed set of instructions. Munich-based Spranic is building a spatial memory layer that records physical spaces and how they change. Connecting that information with knowledge graphs could help robots interpret their environments across different tasks, according to Jordi Spranger (pictured), founder and chief executive […]
AI,
Cube Event Coverage,
NEWS,
#Neo4jDataToKnowledge,
#theCube,
AI luminaries,
Data + AI Turning Data Into Knowledge for Autonomous Systems 2026,
google maps,
graph databases,
graph technology,
John Furrier,
Jordi Spranger,
knowledge graphs,
neo4j,
Neo4jDataToKnowledge26eventpage,
physical AI,
Spranic,
theCUBE + NYSE Wired